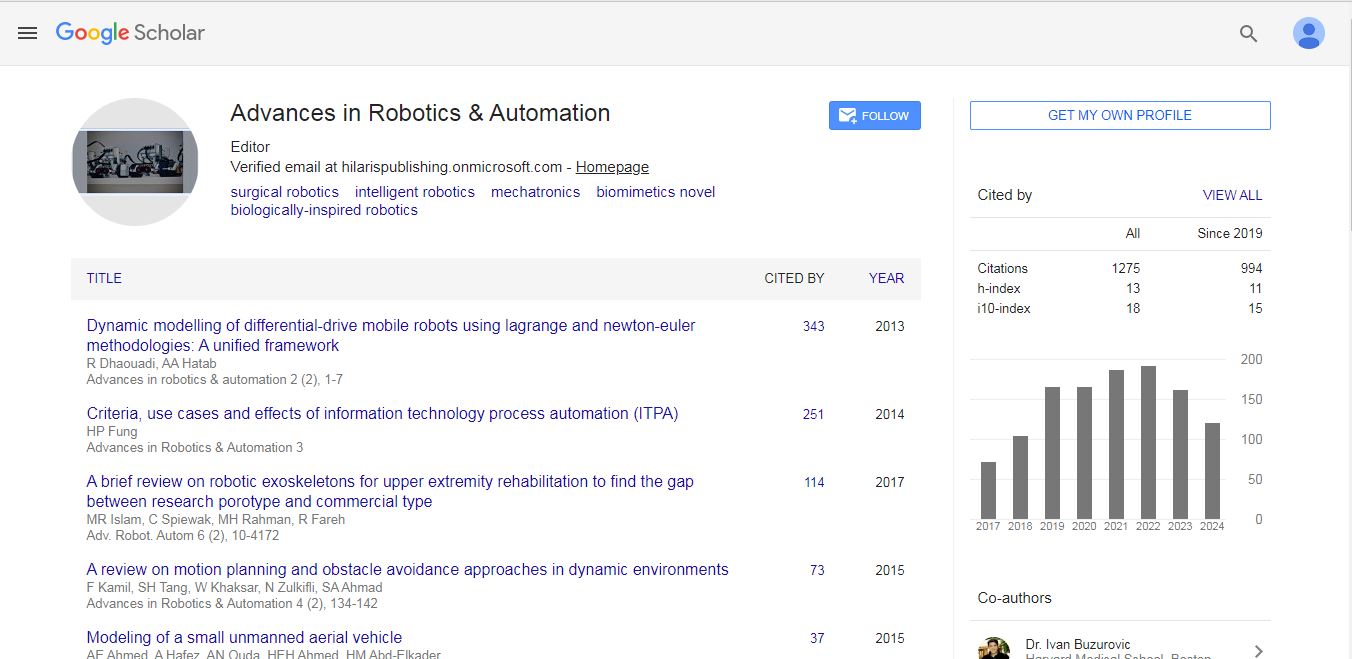
Articles published in Advances in Robotics & Automation have been cited by esteemed scholars and scientists all around the world.
Advances in Robotics & Automation has got h-index 13, which means every article in Advances in Robotics & Automation has got 13 average citations.
Following are the list of articles that have cited the articles published in Advances in Robotics & Automation.
| Journal total citations count | 1275 |
| Journal impact factor | 3.1 |
| Journal 5 years impact factor | 2.7 |
| Journal cite score | 2.43 |
| Journal h-index | 13 |
| Journal h-index since 2019 | 10 |
Anthropomorphic motion control of a gantry robot in assembly cells |
|
Anthropomorphic motion control of a gantry robot in assembly cells |
|
Anthropomorphic motion control of a gantry robot in assembly cells |
|
Anthropomorphic motion control of a gantry robot in assembly cells |
|
Anthropomorphic motion control of a gantry robot in assembly cells |
|
Anthropomorphic motion control of a gantry robot in assembly cells |
|
Anthropomorphic motion control of a gantry robot in assembly cells |
|
Anthropomorphic motion control of a gantry robot in assembly cells |
|
Anthropomorphic motion control of a gantry robot in assembly cells |
|
Anthropomorphic motion control of a gantry robot in assembly cells |
|
Anthropomorphic motion control of a gantry robot in assembly cells |
|
On Configuration Trajectory Formation in Spatiotemporal Profile for Reproducing Human Hand Reaching Movement |
|
On Configuration Trajectory Formation in Spatiotemporal Profile for Reproducing Human Hand Reaching Movement |
|
On Configuration Trajectory Formation in Spatiotemporal Profile for Reproducing Human Hand Reaching Movement |
|
On Configuration Trajectory Formation in Spatiotemporal Profile for Reproducing Human Hand Reaching Movement |
|
On Configuration Trajectory Formation in Spatiotemporal Profile for Reproducing Human Hand Reaching Movement |
|
Performance evaluation of an inverse kinematic based control system of a humanoid robot arm using MS Kinect |
|
General inverse solution of six-degrees-of-freedom serial robots based on the product of exponentials model |
|
Arm Motions of a Humanoid Inspired by Human Motion |
|
An intuitive human robot interface for tele-operation |
|
Advances in Robotics & Automation received 1275 citations as per Google Scholar report

 Spanish
 Chinese
 Russian
 German
 French
 Japanese
 Portuguese
 Hindi
